Modeling a Rotating Link
Kinematically, a kinematic may have one degree of freedom. However, when we want to understand its vibration, it is possible the kinematic-chain is modeled with a many degrees-of-freedom. For example, each link has a degree-of-freedom; and each joint may have 2 or 3 degrees-of-freedom. Other artifacts - backlash, damping, non-linear stiffness - of real mechanisms may also complicate a model further.
However, it is possible to reduce a multi degree-of-freedom model to a single degree-of-freedom model. Usually, the dynamic-properties of the single degree-of-freedom are usually similar to the original many degrees-of-freedom model.
To develop a single degree-of-freedom, we must refer mass moment-of-inertia and torsional-rigidity, or mass and linear-stiffness, of each part in a kinematic-chain to a single mass and stiffness.
We say that we “lump” the mass and stiffness of all of the parts in the kinematic-chain to one place.
Mass Moment-of-Inertia
To calculate the Force to Accelerate a body along a straight-line, you must know the Mass of the body.
To calculate the Torque to Accelerate a body about an axis-of-rotation, you must know the Mass Moment of Inertia of the body about the same axis-of-rotation.
Mass Moment-of-Inertia of a Point-Mass
The Mass Moment-of-Inertia of a Point-Mass (a mass at a point) about an axis-of-rotation is equal to the product of the mass and the square of its distance from the axis-of-rotation.
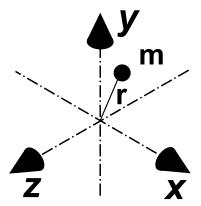 Point Mass at Radius |
Note A Point-Mass is an idealized concept of a mass reduced to a single point without any physical size ... is it a Black Hole? In the image, the Point Mass, , is at a radius, , from the rotating axis, . Its Mass Moment of Inertia, , is:
The SI units of are |
||||||
|
|||||||
Mass Moment of Inertia of a distributed mass.
If we consider a solid body as a distribution of elemental masses, each at a distance from an axis through its Center of Mass, the Mass Moment-of-Inertia of the solid body is the total sum of the product of each mass and square of its radius from the rotational-axis.
Mass Moment of Inertia of geometric shapes
Simple geometric shapes have standard formula that you can use to evaluate the Mass Moment-of-Inertia about an axis through the Center-of-Mass (CoM)
The Mass Moment-of-Inertia, , of a rectangular prismatic body that rotates about the axis, , through the Center-of-Mass, is: |
|||||||||||||||||||
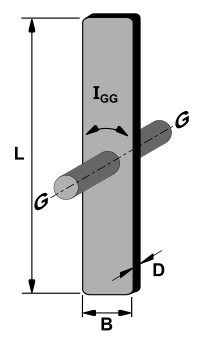 Extruded (Prismatic) Rectangle |
The mass is:
Other geometric-shapes have other standard formula, of course. |
||||||||||||||||||
Parallel Axis Theorem
When you know the Mass Moment of Inertia about an axis passing through the Center of Mass, , you can calculate the Mass Moment-of-Inertia about any other axis that is parallel to . |
|||||||||||
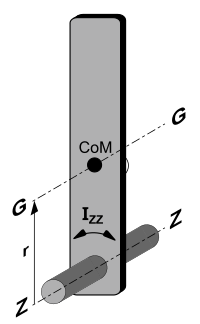 Parallel Axis Theorem |
The image shows the same rectangular link, but now it rotates about the axis , which is parallel to . We use the Parallel Axis Theorem to calculate the Mass Moment of Inertia of the link about the axis .
Note , always , always is always greater than because mass, , is always greater than zero (always positive). and the radius squared, is always positive. |
||||||||||
The Concept of Radius-of Gyration.
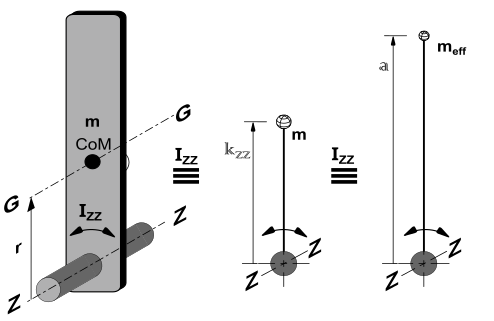
It is sometimes useful to redefine the Mass Moment of Inertia of a body with distributed mass to an equivalent model with a Point-Mass. We want the equivalent model to have the same Mass Moment of Inertia as the original body, about the same axis of rotation. We know that we can replace the Mass Moment of Inertia of a solid body about an axis, with a Point-Mass at a distance from the same axis.
It is possible to use a small mass at a large radius, or a large mass at a small radius. However, if we want the Mass Moment of Inertia AND the Mass to be equal to that of the original model, then the radius is also defined. We call that radius the Radius of Gyration., |
To re-cap, the Mass Moment of Inertia of a body is a function of the axis of rotation. Therefore, the Radius of Gyration is also dependent on the axis of rotation. The images below show the Radius of Gyration for a body rotating around its Center-of-Mass is different from a body rotating around a different axis.
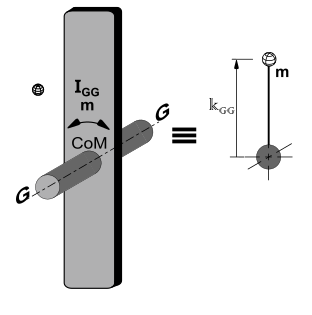 Radius of Gyration from axx through the Center of Mass, CoM
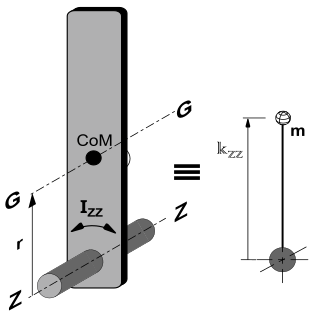 Radius of Gration for an axis parallel to axis through CoM |
To calculate the Radius-of-Gyration, , we need to know the Mass, , and the Mass Moment of Inertia , , and the axis of rotation. To find the Radius of Gyration about an axis or rotation:
Therefore:
|
The Concept of Equivalent-Mass.
It is sometimes useful to specify the Radius from an axis of rotation, such that the Mass Moment of Inertia is equal to that of the solid-body. In that case, the Mass of the Point-Mass must be different from the actual mass of the body. For example, we want the radius to be equal to the length of a lever. We want to find the mass at the end of the lever such that the lever has the same Mass Moment of Inertia as the body. |
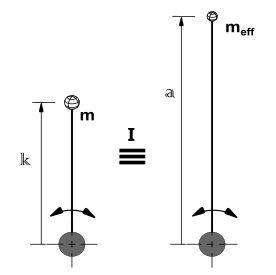 |
|
Transforming Mass across a Lever
Referring a Mass across a Lever
 Reduction of a Effective Mass 'across' a lever ratio Use the Kinetic-Energy of a Mass to equate the Mass at points A and B.
|